 |
Electronic Components Datasheet Search |
|
|
Electronic Components Datasheet Search |
|
L6470PD Datasheet(PDF) 25 Page - STMicroelectronics |
|
|
|||||||||||||||||||||||||||||
L6470PD Datasheet(HTML) 25 Page - STMicroelectronics |
|
|
25 / 70 page 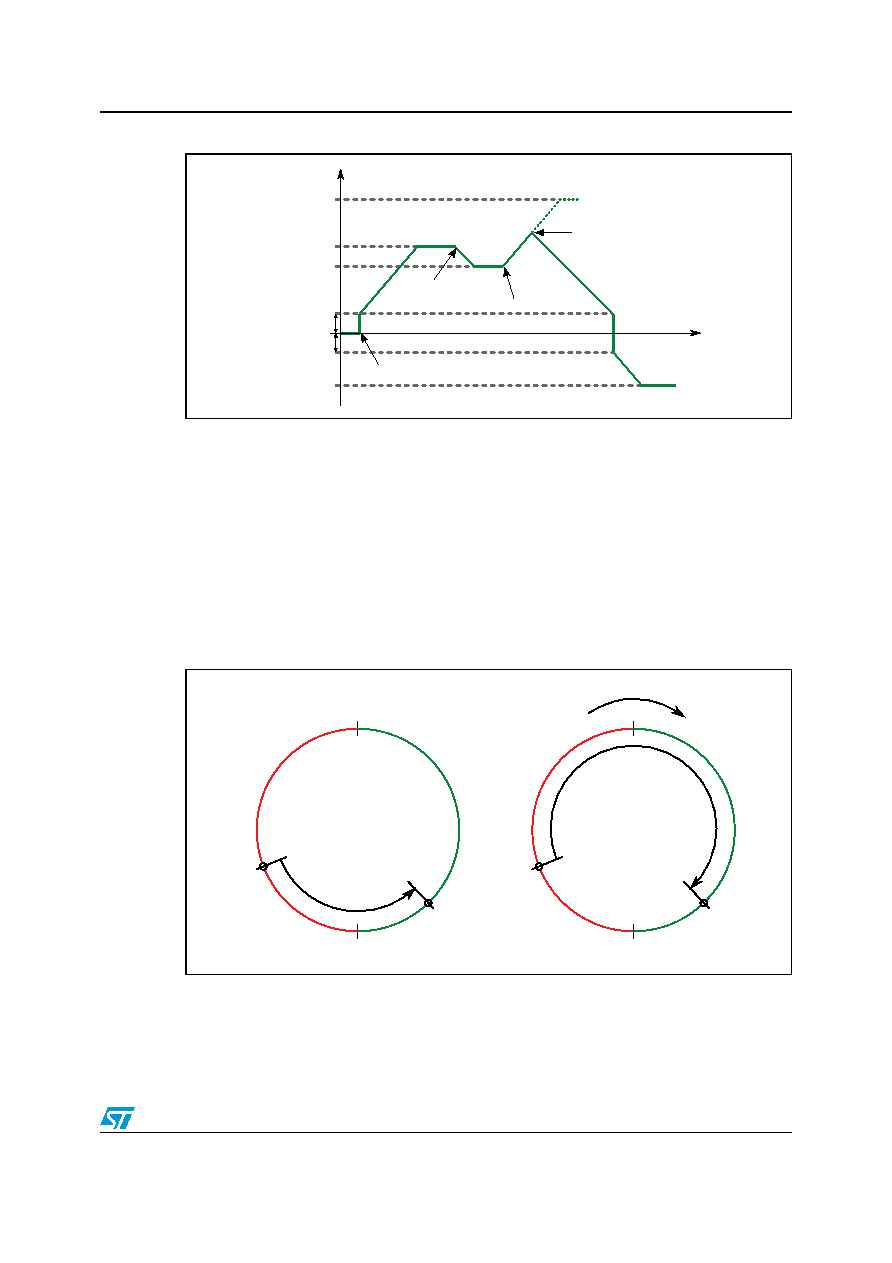 L6470 Functional description Doc ID16737 Rev 5 25/70 Figure 9. Constant speed command examples 6.7.2 Positioning commands An absolute positioning command produces a motion in order to reach a user-defined position that is sent to the device together with the command. The position can be reached performing the minimum path (minimum physical distance) or forcing a direction (see Figure 10). The performed motor motion is compliant to programmed speed profile boundaries (acceleration, deceleration, minimum and maximum speed). Note that with some speed profiles or positioning commands, the deceleration phase can start before the maximum speed is reached. Figure 10. Positioning command examples 6.7.3 Motion commands Motion commands produce a motion in order to perform a user-defined number of microsteps in a user-defined direction that are sent to the device together with the command (see Figure 11). |
|
Link URL |
| Does ALLDATASHEET help your business so far? [ DONATE ] |
About Alldatasheet | Advertisement | Contact us | Privacy Policy | Link to Datasheet | Link Exchange | Manufacturer List All Rights Reserved©Alldatasheet.com |
| Russian : Alldatasheetru.com | Korean : Alldatasheet.co.kr | Spanish : Alldatasheet.es | French : Alldatasheet.fr | Italian : Alldatasheetit.com Portuguese : Alldatasheetpt.com | Polish : Alldatasheet.pl | Vietnamese : Alldatasheet.vn Indian : Alldatasheet.in | Mexican : Alldatasheet.com.mx | British : Alldatasheet.co.uk | New Zealand : Alldatasheet.co.nz |
|
Family Site : ic2ic.com |
icmetro.com |
 New Zealand ▼
 English
 Chinese
 German
 Japanese
 Russian
 Korean
 Spanish
 French
 Italian
 Portuguese
 Polish
 Vietnamese
 Indian
 Mexican
 British
 New Zealand


